48V Servo Drive

Estimate 48V DC supply current, compare a 72V alternative, and prepare motor and battery requirements for a drive RFQ.

Request a 48V drive review / RFQ

48V servo drive current estimator

Compare DC supply current at 48V and 72V; check motor phase current separately.

1–20,000 W at a moving operating point.

1–100%; drive + motor. 100% is ideal only.

1–10× estimated demand; not a torque factor.

No estimate yet. All fields are required; defaults are an illustrative example. Method and limits

Published and reviewed by Custom Robot Servo on . This guide supports preliminary selection; exact drive specifications, availability and quotation require an RFQ review.

What does a 3-phase 48V servo drive mean?

In a DC-fed brushless servo system, 48V describes the nominal DC bus; three-phase describes the inverter output to the motor’s U, V and W terminals. It does not mean a three-phase AC mains input. Confirm the exact drive’s supported motor type, feedback and output-current convention. The calculator estimates DC supply current only. See Texas Instruments: phase-current sensing for 48V servo drives for the circuit arrangement.

Selection guide · DC supply budgeting

What the estimate can help you decide

  1. Use the result for preliminary DC supply budgeting. Drive phase-current selection is a separate check. maxon: input current versus motor current.
  2. Choose voltage from the motor operating points and the full supply envelope. This page establishes no universal 5kW cutoff. maxon: required controller supply voltage.
  3. Compare current ratings on the same basis. For example, Elmo lists 30 A sinusoidal amplitude and 21 A RMS for its Gold Twitter 30/60 variant; these are different conventions, not DC input-current estimates. Elmo: Gold Twitter electrical specifications.
  4. Provide a path for regenerated energy. If available storage cannot absorb it, review a compatible energy-dissipation solution. Synapticon: supply sizing and regenerated energy.
  5. A 48V label does not establish SELV, medical compliance or robot motion safety. Review separation and the complete application. Schneider Electric: SELV circuit requirements; maxon: meaning and limits of STO.

Calculation method and limits

At a moving operating point: Pinput = Pmechanical ÷ efficiency; IDC = Pinput ÷ VDC. The scenario current is IDC × the user-entered demand factor. Efficiency is total drive-and-motor efficiency written as a fraction (85% = 0.85). This is a steady-state energy balance, with no additional reserve, auxiliary load, battery sag or transient model. The factor is an assumption, not a motor overload rating. maxon: input current versus motor current.

48V supply → 235.3 W input / 4.90 A

Drive + motor → 85% assumed efficiency

Shaft → 200 W output + 35.3 W combined losses

Worked example, not a measured product result. Motor phase current is unknown until torque, winding and controller data are supplied.
What is known and what must still be measured or specified
Input / outputStatus and boundary
Mechanical power and efficiencyUser assumptions at one moving operating point; defaults are examples. Tool input ranges are arithmetic limits, not a product capability envelope.
48V and 72V DC bus currentCalculated at fixed nominal voltage. For a different measured voltage, use IDC = Pmechanical ÷ (Vactual × efficiency) separately; this tool does not model voltage sag.
Motor phase RMS / peak currentUnknown. Obtain torque-current data, current convention and duty cycle; never copy the DC estimate into a drive phase-current specification.
Standstill, acceleration and brakingNot modeled. Use torque/thermal data at standstill and time-based motion and energy analysis for transients.
Peak duration, wiring and coolingUnknown. Require component ratings and installation-specific validation. No universal cable gauge, peak duration or temperature limit is supplied.

48V versus 72V: compare the complete system

Analytical comparison at equal output power, assumed efficiency and cable resistance; not a hardware recommendation
Decision factor48V baseline72V alternative
DC bus currentBaseline I2/3 × I (about 33% less); phase current is a separate check
DC cable lossBaseline I²R4/9 × I²R (about 56% less) for unchanged resistance; other losses are not predicted
Motor speed / torqueConfirm points at minimum bus voltageCheck voltage headroom and all motor/drive limits
Integration costMay retain an existing supply and charger if compatibleReview supply, charger, auxiliaries, harness and validation cost
Regeneration / safetyDocument absorption and protective designReassess voltage limits and protection across every connected component

The ratios follow the stated power model. Architecture selection still needs the motor curve and voltage checks described by maxon: required controller supply voltage.

Three reproducible sizing scenarios

Illustrative moving operating points at 85% efficiency; values rounded to 2 decimals, no design reserve
Assumption48V → 72V bus currentNext decision
80 W lab axis, 2× demand1.96 A → 1.31 A; 2× scenario: 3.92 A → 2.61 ACheck the existing 48V supply and actual phase-current ratings before changing architecture.
200 W mobile axis, 3× demand4.90 A → 3.27 A; 3× scenario: 14.71 A → 9.80 ACheck BMS discharge duration, loaded voltage and regenerative charge acceptance.
600 W moving axis, 2× demand14.71 A → 9.80 A; 2× scenario: 29.41 A → 19.61 ACompare harness, cooling and architecture cost; this estimate alone does not approve either voltage.

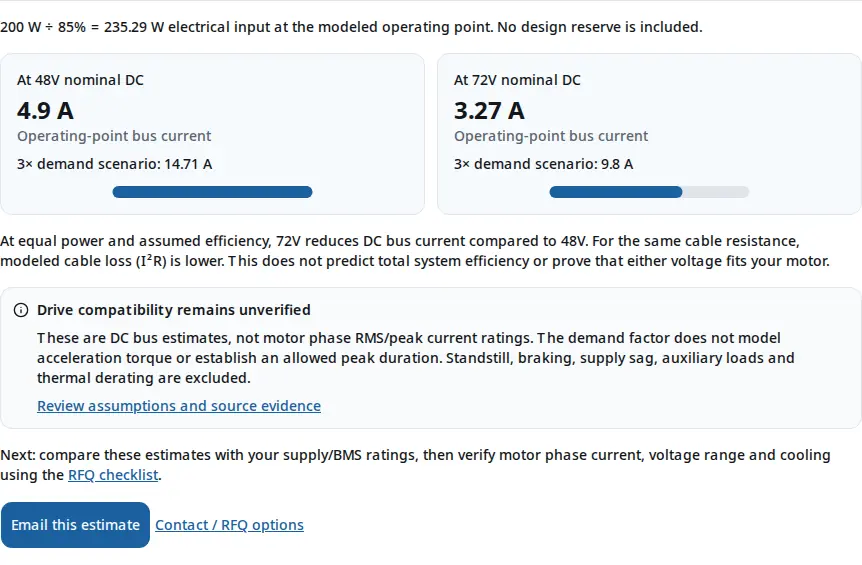
Reproduce each row using the estimator with 85% efficiency. Example: 200 ÷ (48 × 0.85) ≈ 4.90 A; the 3× scenario is 14.71 A using unrounded intermediate values.

View the reproduced 200 W calculator output
48V servo drive calculator at 200 W, 85% efficiency and 3× demand: 4.9 A at 48V and 3.27 A at 72V.
Actual browser output captured on 21 September 2026. This records software execution with illustrative inputs, not a hardware test or customer result. The scenario values are 14.71 A and 9.8 A; the unrounded calculation determines both results.

48V boundaries: when to reconsider the architecture

Engineering checks, not universal thresholds or product certification
ConstraintEvidence and boundaryNext action
Supply demand and thermal limitsNo universal 5kW ceiling. For illustration, 5,000 W electrical input ÷ 48V = 104.17 A DC; mechanical output and permitted duration remain separate.Check supply, DC harness and phase-current ratings separately. Compare cooling, winding, gearing and voltage alternatives. maxon: input current versus motor current.
Regenerative overvoltageNo universal trip voltage. The Elmo Gold Twitter 30/60 table lists 48V nominal and 55V maximum supply; a maximum rating is not a trip setpoint.Obtain the exact drive limits and BMS charge acceptance. Size a compatible absorption or dissipation path for braking energy and repetition. Elmo: Gold Twitter electrical specifications; Synapticon: supply sizing and regenerated energy.
Required speed and torqueA nominal voltage label does not establish the achievable operating points under load.Review motor constants and drive output-voltage limits at the minimum loaded supply. Compare suitable winding, gearing or supply changes. maxon: required controller supply voltage.

A nominal 48V supply does not establish SELV. Protective separation, grounding and normal and single-fault conditions require assessment; full-charge and regenerated voltage also matter. This page makes no compliance claim for either voltage. Schneider Electric: SELV circuit requirements.

Sources, dates and evidence limits

Sources checked on . Manufacturer examples explain selection principles; they do not certify or establish ratings for a Custom Robot Servo product. Published performance, lead time and price for your proposed configuration remain to be confirmed. Tables below are RFQ and validation requirements, not test results.

Primary references used in this guide
ReferenceDate / scope
Texas Instruments: phase-current sensing for 48V servo drivesSBAA666, Figure 1-1; checked 21 Sep 2026. DC supply and three-phase inverter topology, not a complete drive specification.
maxon: input current versus motor currentUpdated 29 Aug 2024. PWM power conversion; not a product rating.
maxon: required controller supply voltageUpdated 4 Apr 2023. Operating-point voltage, sag and charging considerations.
Elmo: Gold Twitter electrical specificationsLive product table, checked 21 Sep 2026. Exact variant and current convention matter.
Synapticon: supply sizing and regenerated energyDocumentation 5.6.35, built 9 Sep 2026; checked 21 Sep 2026. Supply and energy-path principles; SOMANET ratings are not universal drive limits.
Schneider Electric: SELV circuit requirementsModified 20 Aug 2024. Protective separation and fault conditions; not a certificate.
maxon: meaning and limits of STOUpdated 29 Aug 2024. Torque removal does not define stopping or holding behavior.

Source discrepancy: Elmo’s live Gold Twitter highlights list a 6V lower bound for the 60V family, while the 30/60 electrical table lists 8V. Resolve supply limits against the exact variant’s current hardware manual before selection; neither value is adopted as a general 48V-drive limit.

Turn the estimate into a drive specification

Send the motor curve, supply voltage envelope and time-based duty cycle for review. The checklist below identifies the remaining evidence needed for a configuration-specific quotation.

Review motor data for a 48V drive RFQ

Selection Priorities

  • Budget 48V supply demand at a moving operating point; confirm motor phase current independently.
  • Compare 72V only after checking motor voltage headroom, charging limits and integration cost.
  • Define peak duration, cooling and regenerated-energy handling before selecting a drive.

Application Fit — Subject to Validation

  • AMR and AGV axes with verified battery discharge and regenerative charge acceptance
  • Robot joints with validated torque-speed points and a separate motion-safety design
  • Lab axes with documented duty cycle, feedback and enclosure cooling
  • Quadruped platforms with measured simultaneous-axis supply demand

Engineering Focus Areas

DC supply current versus motor phase RMS and peak current48V / 72V voltage headroom and complete integration costBMS charge acceptance, braking energy and thermal duty

Specification Status and Required Evidence

MetricValue / Evidence StatusEngineering Impact
DC supply currentCalculated: 11.84 A at 500 W / 48V / 88%Illustrative moving operating point without design reserve; not a drive phase-current rating.
Phase current and mechanical outputUnknown until motor, drive and cooling are specifiedRequire continuous and peak ratings with current convention, duration, repetition and thermal derating. No 5kW product capability is established here.
Supply envelope and regenerative limitsExact model and configuration requiredDistinguish operating maximum, absolute maximum, fault threshold and braking-clamp settings; do not assume a universal 60V trip.
Functions, availability and quotationNot established by this page; confirm in the RFQObtain evidence for feedback, protocol, safety functions, software, price and delivery for the exact configuration.

Selection Logic

SituationRecommended PathEvidence to Confirm
Choosing between 48V and 72VCompare motor voltage headroom, DC supply demand, cooling and complete integration cost. Retain 48V when it meets the required operating envelope.Motor curves at minimum loaded voltage; phase-current ratings; DC supply/BMS and harness ratings; charger and auxiliary-device compatibility.
Full-charge battery with repeated decelerationConfirm regenerative charge acceptance and an energy path before selecting protection. Evaluate dissipation or storage if the existing supply cannot absorb the energy.Braking energy, repetition, synchronized drive/BMS logs and documented voltage, energy and thermal limits for every connected component.
High peak demand in a compact jointCheck torque and phase current independently of the bus estimate. Compare cooling, winding, gearing and supply options against the full motion profile.Current convention, peak magnitude/duration/repetition, installation thermal tests, speed limits and total architecture cost.

RFQ Checklist

  1. Motor model, torque-speed points, Kt / Ke, phase resistance/inductance and RMS versus amplitude convention
  2. Minimum loaded, nominal and maximum charged bus voltage; BMS discharge and charge acceptance limits
  3. Peak magnitude, duration, repetition, simultaneous axes and auxiliary power demand
  4. Cooling interface, ambient range, enclosure, cable lengths and connector specifications
  5. Braking energy and repetition, available absorption path and exact overvoltage limits
  6. Encoder model, protocol/version, safety requirements, drawings, quantity, target date and acceptance criteria

Risk Controls

  • Current or duty-cycle mismatch: Size DC wiring from supply current and phase wiring from motor current. Confirm cooling and the permitted peak duration from exact component data; the demand factor grants no overload capability.
  • Overvoltage during braking: Check full-charge BMS acceptance and every connected component limit. Review a compatible storage, regenerative supply or chopper/resistor solution with the supplier when existing absorption is insufficient.
  • Architecture change cost: Compare supply, charger, harness, auxiliary converters, cooling and requalification costs for 48V and 72V. Lower modeled bus current alone does not establish a cheaper system.
  • Motor or application mismatch: Verify required torque and speed at the minimum bus voltage. Review winding, gearing or voltage alternatives if needed; assess stopping and holding separately for gravity-loaded axes.

Validation and QC Flow

CheckpointMethodPass Evidence
Voltage spike protectionOn a secured setup, begin with low-energy trajectories and increase only within a reviewed test plan. Monitor DC voltage and the energy-absorption path, including the defined full-charge condition.Measured voltage, energy and temperatures remain within exact component operating limits and agreed margins; no universal 60V pass criterion.
Phase current and thermal dutyRecord DC input and motor phase current separately during the agreed duty cycle, cooling arrangement and ambient conditions.Peak magnitude, duration and repetition and stabilized temperatures satisfy documented motor, drive, harness and supply limits.
Motor and interface compatibilityVerify agreed torque-speed points at minimum supply voltage, encoder feedback and protocol behavior on the approved sample setup.Recorded operating points and interface behavior meet the signed acceptance plan; required safety functions have separate documentation and validation.

Download RFQ and Validation Templates

Use these templates before sending a 48V Servo Drive inquiry so torque-speed data, drawings, thermal assumptions, and sample acceptance evidence arrive in one package.

CSV

Servo RFQ Baseline Checklist

A field-by-field checklist for torque-speed-duty targets, drawings, protocol, sample quantity, acceptance tests, and open decisions.

Use before the first supplier email so engineering, sourcing, and procurement are aligned on required inputs.

CSV

CSV

Servo Validation Plan Template

A starting validation matrix for torque, current, heat rise, backlash, encoder zero, communication, burn-in, and outgoing inspection.

Use when samples are being scoped and the buyer needs pass/fail evidence before pilot approval.

CSV

CSV

Thermal Derating Worksheet

A compact worksheet for comparing ambient, housing, winding, duty cycle, current limit, and sealed-joint thermal margin.

Use when peak torque looks acceptable but continuous-duty heat rise is still the main project risk.

CSV

Buyer FAQ

Calculator and current

Does the estimator select a drive phase-current rating?

No. It estimates nominal DC supply demand. Match motor phase RMS and peak current using torque-current data and the drive current convention, as explained by the current-conversion reference in the guide.

What does the 88% efficiency default mean?

It is an illustrative drive-plus-motor assumption at one moving point, not measured performance. Enter efficiency for your operating point. If output power is measured after a gearbox, include its losses too. At 100%, the result is an ideal lower bound.

Does the demand factor establish a peak duration?

No. It multiplies an assumed DC demand scenario. Acceleration torque, motor phase current, duration and repetition require a motion profile and the exact motor/drive limits. The default 3× is not an overload rating.

Can I calculate a holding joint at zero watts?

No. This moving-point power model rejects zero. A stationary motor can still need current and cooling; supply holding torque, winding and thermal data through the RFQ checklist instead.

Architecture and motor fit

When should I compare 72V with 48V?

Compare it when the 48V motor operating points, supply or harness constraints do not fit. At equal power and assumed efficiency, 72V needs two-thirds of the 48V DC current. Check all voltage ratings, charger and auxiliary changes, and total cost before adopting it.

Is 5kW the universal limit for a 48V servo drive?

No universal limit or 5kW product capability is established here. Feasibility depends on motor operating points, current ratings, voltage headroom, cooling and duty cycle. Electrical input power must not be presented as mechanical output.

Can a nominal 24V motor run on a 48V drive?

The nominal labels alone cannot confirm compatibility. Have the motor and drive supplier verify operating-point voltage, PWM/insulation limits, winding current, feedback and mechanical speed limits. See the controller supply-voltage reference above.

Can I connect a nominal 48V battery directly?

Only after confirming minimum loaded voltage, maximum charge voltage, transients and BMS behavior against the exact drive and connected components. A nominal 48V label does not specify the full operating envelope.

Protection and purchasing

Do all 48V drives trip at 60V?

No. Obtain exact operating, absolute maximum and fault thresholds. For example, the linked Elmo 30/60 table lists a 55V maximum supply; this is neither a universal limit nor a trip setting for other drives.

What if the battery cannot accept regenerated energy?

Record the energy per braking event, repetition, bus voltage and BMS charge acceptance. Use the regenerated-energy reference to review a compatible absorption or dissipation path, then validate it within documented limits.

Does 48V establish SELV or include STO?

Neither is established by the bus voltage. SELV requires protective separation and fault-condition assessment. Request any required STO documentation for the exact drive; torque removal alone does not provide controlled braking or gravity-load holding. See the safety sources above.

Are EtherCAT, absolute encoders and tuning software included?

Support is unconfirmed until a configuration is agreed. Send the controller protocol/version, encoder model and software requirements; request interface documentation, configuration tools and sample validation before purchase.

What price and lead time can I expect?

This page provides no verified price, stock or delivery schedule. Request a quotation against the motor data, drawings, firmware scope, quantity, acceptance plan and target date. Confirm sample and production schedules separately.

What cooling evidence should accompany an RFQ?

Provide the mounting interface, enclosure, ambient range and time-based duty cycle. Request thermal derating data and tests using the agreed cooling arrangement; no universal cold-plate or peak-duration capability is assumed.

Related Resources

Inquiry Email

[email protected]

Include drawings, torque/speed, protocol, and prototype quantity.

Instant Chat

+8618857971991

Direct response from our engineering team.