Solutions

Solutions & Applications

Select application scenarios to review recommended motion architectures, capability fit, and OEM support direction.

Each solution page is written for buyer-side decisions: what to validate first, where project risk usually appears, and what data should be included in the initial RFQ to avoid quote loops.

Application Selection Workflow

  1. Map your machine module and axis motion profile.
  2. Define performance acceptance criteria with measurable limits.
  3. Match solution architecture to control stack and thermal envelope.
  4. Freeze prototype validation gates before PO release.
Custom Robot Servo robotics servo solution

CANopen Servo Drive for Collaborative Robot Wrists

Evaluate miniature CANopen servo drive architectures for collaborative robot wrists with tool payload inertia calculations, phase/DC current and illustrative thermal screening, CiA 402 bus timing, and holding brake safety boundaries.

Cobot wrist mechatronics engineers, robotics hardware leads, and automation designers specifying compact servo drives for end-of-arm manipulation.

  • Interactive wrist kinematics and cantilever gravity/inertia torque evaluator
  • Compare annular and shared dual-axis boards against CAD, thermal and service constraints
  • Separate DC-input current from phase current at 24V and 48V; qualify the shared thermal path
View details
Custom Robot Servo robotics servo solution

CANopen Servo Drive for Cobot Joints

Screen CANopen servo drive requirements for collaborative robot joints with a current and bus-load evaluator, thermal assumptions, CiA 402 integration guidance and explicit safety evidence boundaries.

Cobot hardware system architects, joint actuator engineers, and OEM robotics program leads developing custom collaborative arms.

  • Interactive joint sizing & CANopen bus bandwidth utilization evaluator
  • Compare annular and compact board layouts against the actual CAD and cable envelope
  • Evaluate encoder interfaces, reducer compliance and measured resonance before tuning
View details
Dual encoder humanoid robot servo joint system

Humanoid Robot Servo Systems

Custom servo systems for humanoid robot joints, hands, necks, and torso modules where torque density, compact electronics, and thermal control define success.

For humanoid hardware teams that need custom servo hardware faster than a fully internal supply chain can be built.

  • Joint-level review across motor, reducer, drive, encoder, brake, bearing, housing, and harness
  • Support for quasi-direct-drive and geared servo architectures
  • Prototype, pilot, and batch-production sourcing coordination
View details
Micro servo control board for robotic gripper integration

Robotic Gripper Servo Integration

Compact custom servo motors, micro drives, smart servos, and actuator assemblies for grippers, end effectors, and dexterous hand mechanisms.

For end-effector teams that need small, reliable, controllable servo hardware inside tight mechanical packaging.

  • Micro servo layouts for narrow fingers and compact gripper cavities
  • Torque, compliance, encoder, cable, and firmware integration support
  • Manufacturing review for small gears, housings, shafts, PCBA, and calibration fixtures
View details
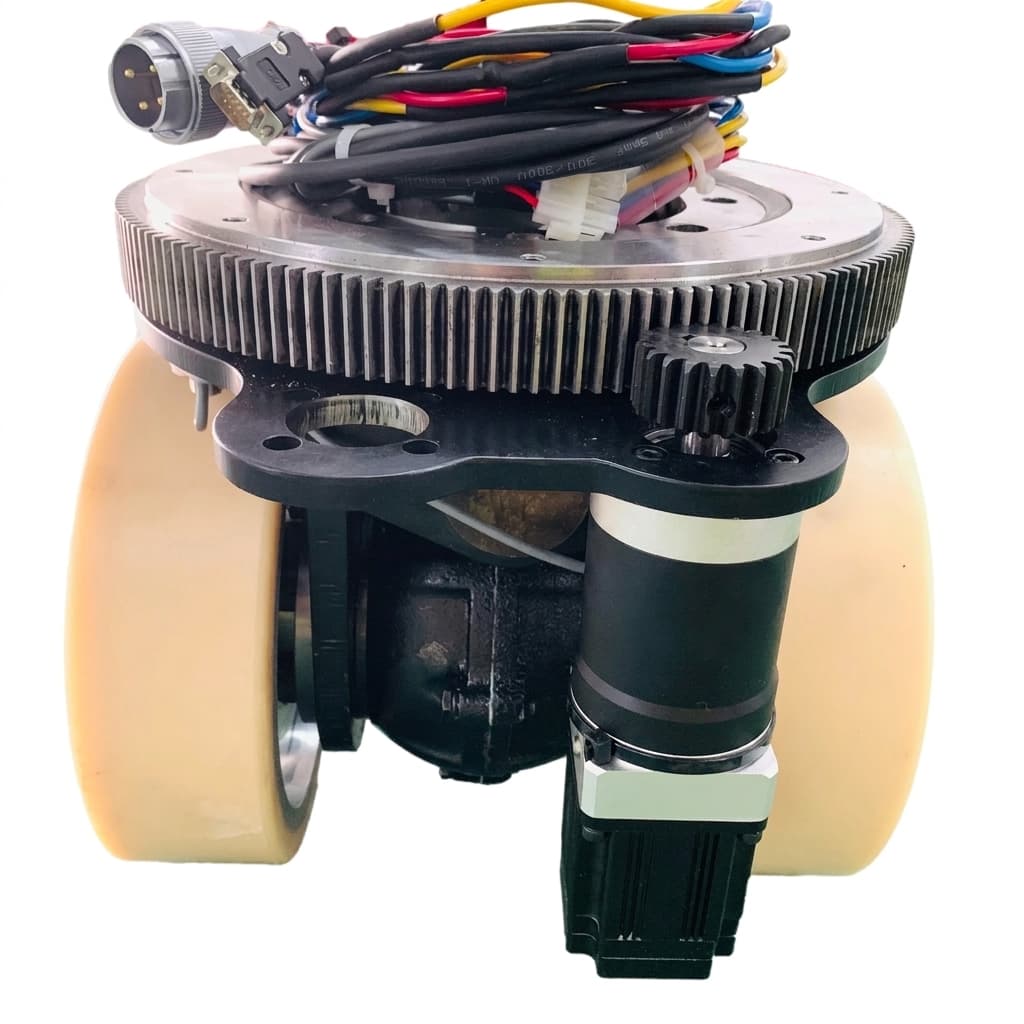
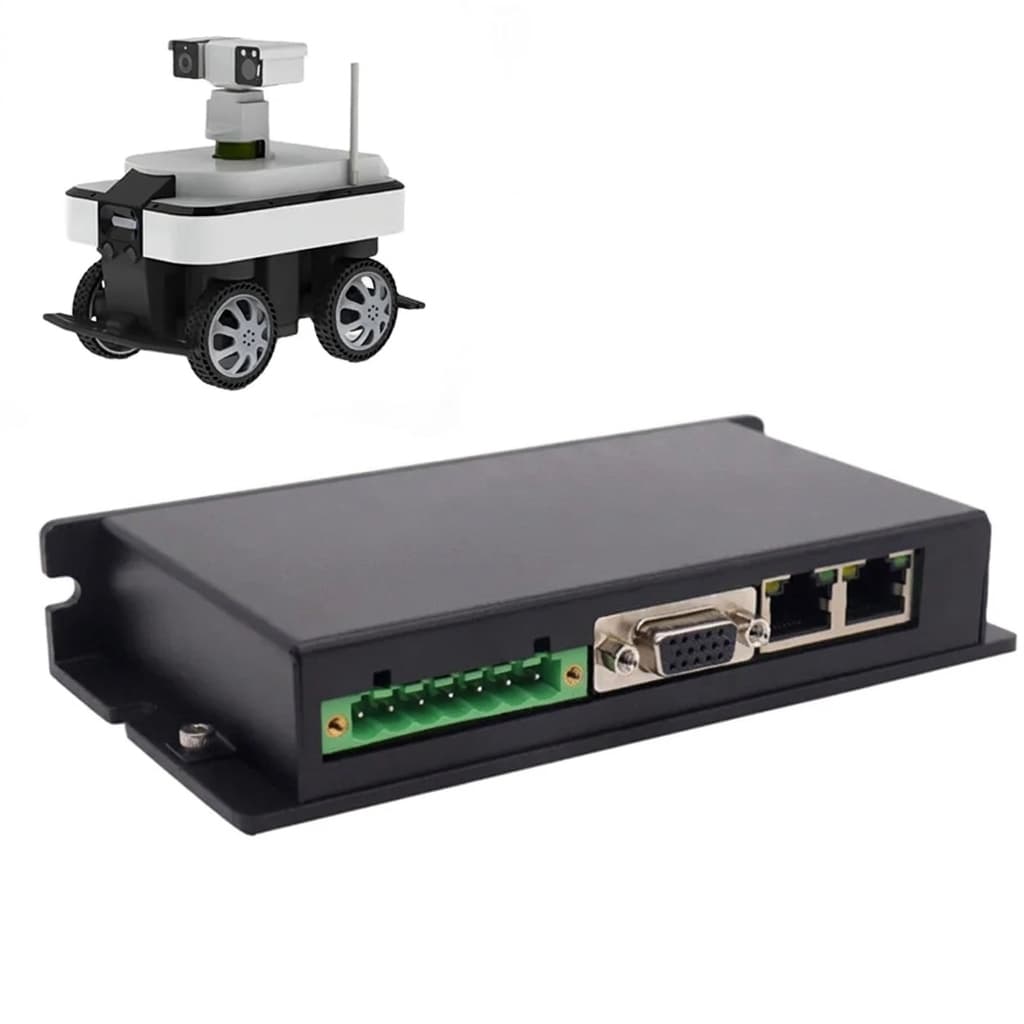
Precision servo electronics for mobile robot platforms

Mobile Robot Servo Platforms

Custom servo motors, drives, and integrated actuation modules for AGV, AMR, inspection, delivery, and field robot platforms.

For mobile robot builders that need robust servo hardware under vibration, battery voltage variation, and repeated field duty.

  • Low-voltage battery-powered servo drive and motor matching
  • Steering, suspension, sensor mast, lift, and manipulator servo modules
  • Export-oriented sourcing support for prototype fleets and repeat production
View details
Driver encoder servo stack for compact medical robot modules

Medical Robot Servo Modules

Custom compact servo motors, servo drives, and integrated modules for medical robot prototypes, surgical tool positioning, lab automation, and controlled motion systems.

For medical and lab automation teams that need engineering-grade servo customization with disciplined documentation.

  • Precision positioning focus with low noise, smooth motion, and controlled heat rise
  • Custom cabling, compact electronics, encoder integration, and documentation support by project scope
  • Prototype and pilot-build coordination for regulated-device development teams
View details

Solution Comparison Snapshot

SolutionPrimary Buyer FocusKey MetricWhy It Matters
CANopen Servo Drive for Collaborative Robot WristsCobot wrist mechatronics engineers, robotics hardware leads, and automation designers specifying compact servo drives for end-of-arm manipulation.Weight & Power Density: Unknown until the board layout and mechanical envelope are agreedWrist mass affects upstream inertia and the available load envelope according to its position and motion.
CANopen Servo Drive for Cobot JointsCobot hardware system architects, joint actuator engineers, and OEM robotics program leads developing custom collaborative arms.Bus Cycle & Update Frequency: Example cycles only; derive from the complete PDO and traffic budgetBudget arbitration delays, other traffic and actual deadlines; the model cannot establish timing on hardware.
Humanoid Robot Servo SystemsFor humanoid hardware teams that need custom servo hardware faster than a fully internal supply chain can be built.Joint torque class: Finger, wrist, elbow, knee, ankle, hip, shoulderEach joint has a different torque, size, and thermal tradeoff.
Robotic Gripper Servo IntegrationFor end-effector teams that need small, reliable, controllable servo hardware inside tight mechanical packaging.Servo size class: Micro to compact smart servoThe gripper envelope often limits motor diameter, board area, and connector choice.
Mobile Robot Servo PlatformsFor mobile robot builders that need robust servo hardware under vibration, battery voltage variation, and repeated field duty.Battery bus: 24 V, 36 V, 48 V, 60 V, or customMobile robot servo drives must tolerate voltage sag, current spikes, and regen events.
Medical Robot Servo ModulesFor medical and lab automation teams that need engineering-grade servo customization with disciplined documentation.Motion smoothness: Defined by positioning and noise targetMedical and lab equipment often values controllability and repeatability over raw peak torque.

Inquiry Email

[email protected]

Include drawings, torque/speed, protocol, and prototype quantity.

Instant Chat

WhatsApp Engineering Support

Direct response from our engineering team.